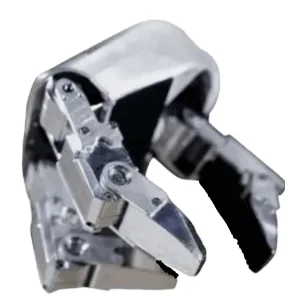
Dex5-1P Five-Finger Hand for H2 (Tactile)
Unitree Dex5-1P five-finger dexterous hand for the H2, with 94 pressure sensors. A repair part, ordered with the H2.
Description
The Dex5-1P adds tactile sensing to Unitree’s Dex5-1 five-finger hand, with 12 sensor arrays and 94 pressure sensors across the palm and fingers.
Unitree supplies it as a repair part only. It cannot be ordered separately and must be ordered together with an H2. Price and specifications are per hand, so specify left or right.
| Specification | Dex5-1P |
|---|---|
| Specifications | |
| Degrees of freedom | 16 active |
| Fingers | Thumb 4, index 3, middle 3, ring 3, little 3 |
| Minimum grasping diameter | 10 mm |
| Fingertip repeatability | ±1 mm |
| Fingertip force | 10 N |
| Load | 3.5 kg palm down, 4.5 kg palm sideways, gripping a 5 cm rigid cylinder |
| Operating voltage | 24 to 60 V |
| Current | 58 V at 0.2 A quiescent, 58 V at 3 A maximum |
| Communication | USB 2.0 at 1000 Hz |
| Operating temperature | -20 to 60 °C |
| Tactile sensors | 12 arrays, 94 pressure sensors |
| Sensing range | 10 g to 2500 g |
| Maximum force without damage | 20 kg |
Source: Unitree Robotics published specifications and Stokes Robotics product data.
Additional information
| Product Type | Repair Part |
|---|---|
| Manufacturer | Unitree |
| Compatible With | Unitree H2 EDU |